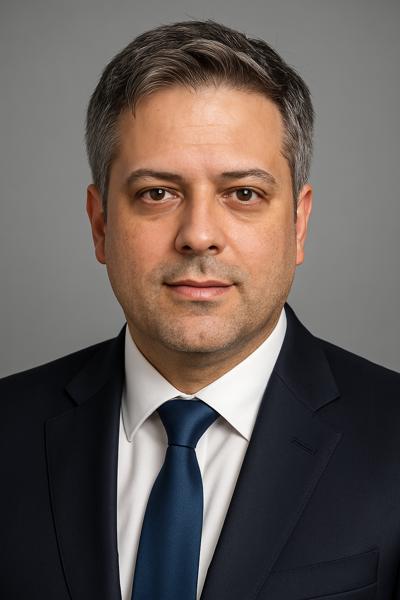
Dr. Kaveh Hooshmandi
Dr. Kaveh HooshmandiI am an Assistant Professor in Control Engineering at the Department of Electrical Engineering, Arak University of Technology, Iran, and the Founder and CEO of Smart Rabo Company. My work focuses on control systems, robotics, autonomous mobile robots, automation, mechatronics, embedded systems, sensor fusion, state estimation, and ROS2-based robotic system development. My academic background is in nonlinear and robust control, sampled-data systems, linear parameter-varying (LPV) systems, observer-based estimation, state estimation, and practical control implementation. I am particularly interested in connecting rigorous control theory with real engineering systems, including robotic platforms, autonomous navigation systems, embedded controllers, and industrial automation applications. Alongside my academic role, I lead industry-oriented projects at Smart Rabo Company, including autonomous mobile robot development, embedded control, sensor and actuator integration, electronics integration, prototype fabrication, testing, and system validation. This combined academic and industrial experience enables me to work at the intersection of theory, implementation, and technology translation. |
Research Interests
Control Systems and AutomationMy research includes nonlinear control, robust control, LPV control, sampled-data systems, observer-based control, and control of uncertain and nonlinear systems. I am interested in developing control methods that are both theoretically sound and practically implementable. Robotics and Autonomous SystemsI work on autonomous mobile robots, robotic navigation, motion control, trajectory tracking, SLAM, localization, and ROS2-based robotic architectures. My applied work involves the integration of LiDAR, IMU, encoders, motor drivers, embedded controllers, and perception modules for autonomous operation. | Sensor Fusion and State EstimationMy interests include Kalman filtering, adaptive estimation, observer design, multi-sensor fusion, and localization using LiDAR, IMU, encoders, and other onboard sensors. I am particularly interested in robust estimation methods for uncertain and dynamic environments. Embedded Systems and MechatronicsMy engineering activities include embedded implementation, microcontroller-based control, actuator and sensor interfacing, hardware-software integration, mechatronic prototyping, and validation of real-time robotic and automation systems. |
Selected Publications
Improved sampled-data synchronization in chaotic Lur’e systems via a two-layer LPV framework K. Hooshmandi, S. Mobayen, and A. Samimi This work develops a two-layer LPV framework for improved sampled-data synchronization of chaotic Lur’e systems, contributing to robust control and nonlinear system analysis. Synthesizing robust observer-based guaranteed cost LPV control for artificial pancreas systems under input saturation K. Hooshmandi, S. Mobayen, and A. A. Zhilenkov This study presents an observer-based guaranteed cost LPV control approach for nonlinear biomedical systems subject to input saturation and uncertainty. Sampled-data LPV approach for voltage regulation of DC--DC buck converter K. Hooshmandi, F. Bayat, and A. Bartoszewicz This paper applies sampled-data LPV control to voltage regulation in power electronic converters, linking control theory with electrical engineering applications. Polynomial LPV approach to robust H∞ control of nonlinear sampled-data systems K. Hooshmandi, F. Bayat, M. R. Jahed-Motlagh, and A. A. Jalali This research proposes a polynomial LPV framework for robust H∞ control of nonlinear sampled-data systems. A complete list of publications is available on my Google Scholar profile. |
Applied Projects and Industrial Work
Autonomous Mobile RobotsThrough Smart Rabo Company, I contribute to the design and development of autonomous mobile robot platforms for industrial and real-world applications. These systems integrate ROS2, LiDAR, IMU, encoders, motor drivers, navigation, localization, and control modules. ROS2-Based Robotic SystemsMy work includes modular robotic software architectures for perception, planning, localization, monitoring, and motion control using ROS2 and Linux-based development environments. | Industrial Automation and Embedded ControlI work on embedded control systems, sensor and actuator integration, electronics interfacing, prototype development, and system-level validation for automation and mechatronic applications. Hardware-Software IntegrationMy practical engineering experience includes connecting control algorithms with real hardware through embedded systems, motor drivers, sensors, microcontrollers, and robotic software stacks. |
Teaching and Supervision
I teach and supervise students in areas related to control engineering, robotics, automation, mechatronics, modelling and simulation, embedded systems, state estimation, and engineering applications. My teaching approach emphasizes practical engineering, project-based learning, simulation, laboratory work, implementation, debugging, and experimental validation.
Selected teaching and supervision areas include:
- Control Systems and Modern Control Engineering
- Nonlinear and Robust Control
- Robotics and Autonomous Systems
- Mechatronics and Embedded Systems
- MATLAB/Simulink Modelling and Simulation
- State Estimation and Sensor Fusion
- Engineering Programming and Practical Implementation
- Undergraduate and Postgraduate Project Supervision
Professional Profile
- Assistant Professor in Control Engineering, Arak University of Technology
- Founder and CEO, Smart Rabo Company
- Researcher in control systems, robotics, automation, and mechatronics
- Developer of autonomous mobile robot and embedded control platforms
- Reviewer for international journals in control, robotics, and nonlinear systems
Contact
For collaboration, research, supervision, or industrial projects, please contact me via:
- Email: dk.hooshmandi@gmail.com
- Academic Email: k.hooshmandi@arakut.ac.ir
- GitHub: github.com/kaveh-hooshmandi
- Google Scholar: Google Scholar Profile